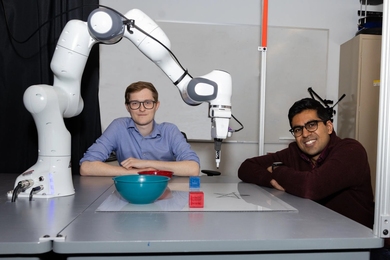
The “PRoC3S” method helps an LLM create a viable action plan by testing each step in a simulation. This strategy could eventually aid in-home robots to complete more ambiguous chore requests.
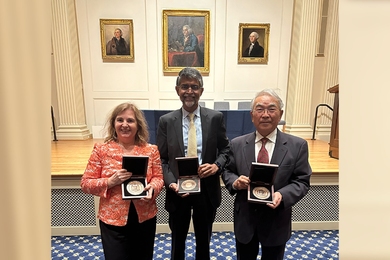
MIT CSAIL director and EECS professor named a co-recipient of the honor for her robotics research, which has expanded our understanding of what a robot can be.
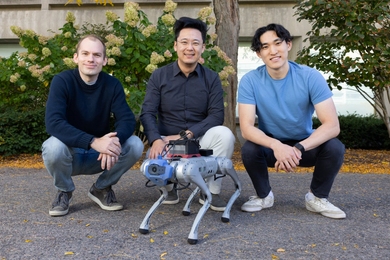
MIT CSAIL researchers used AI-generated images to train a robot dog in parkour, without real-world data. Their LucidSim system demonstrates generative AI's potential for creating robotics training data.